


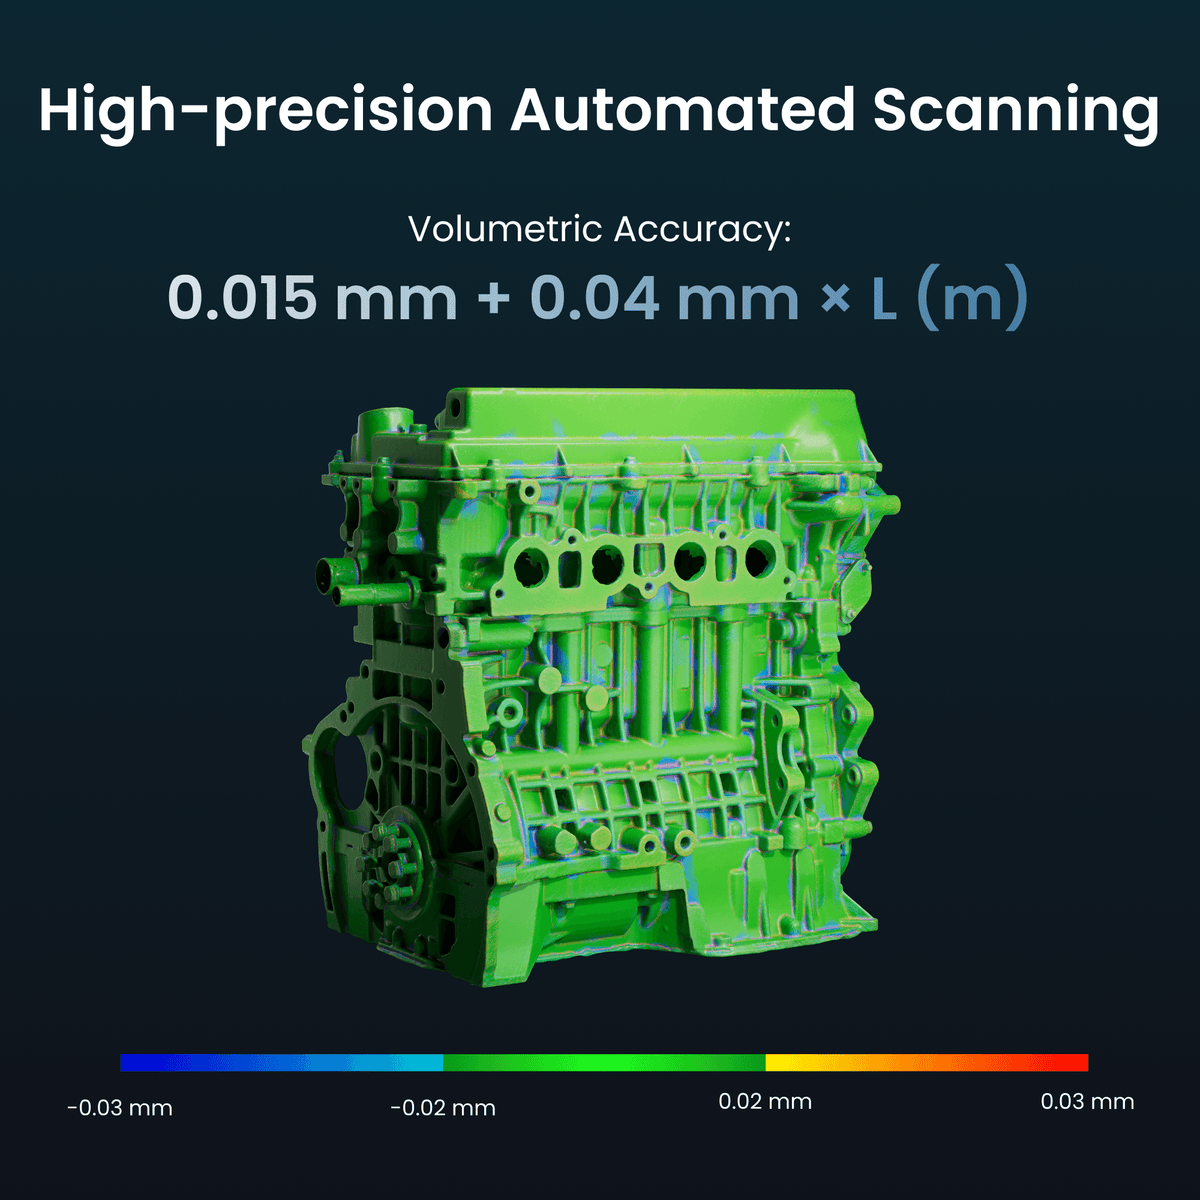
High-precision
Automated Scanning
Automated multi-angle scanning covers complex workpieces up to 0.5 m.
Volumetric Accuracy:
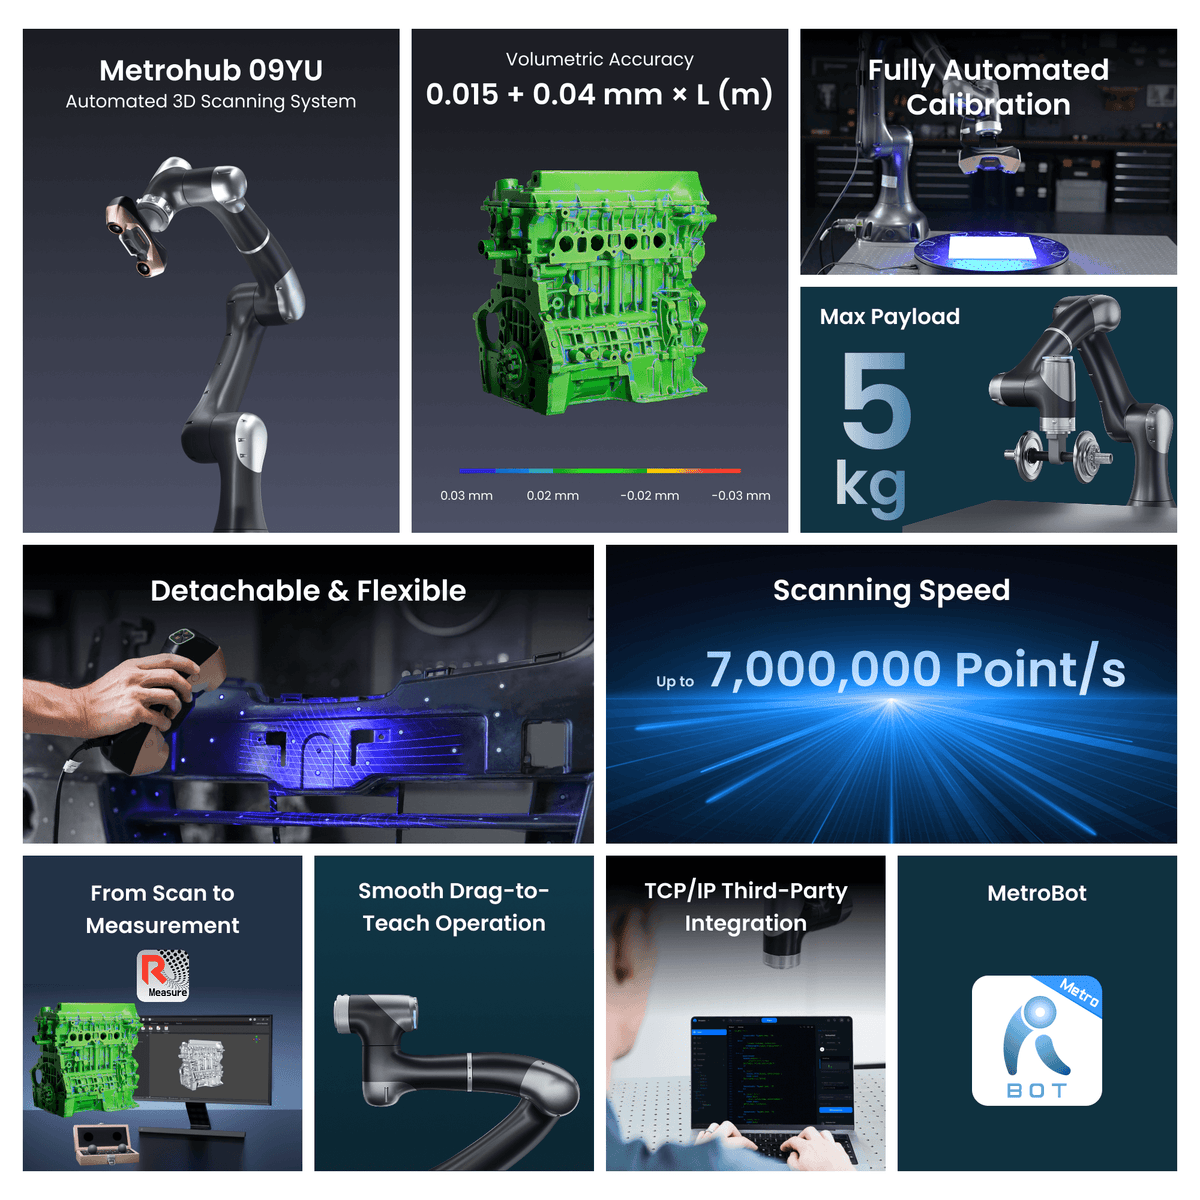
0.015 mm + 0.04 mm × L (m)
Agile Motion:
6-axis, ±360° Movement



New
Automated
Flexible
Usually, free shipping for most 3D scanners, 3-5 working days fast receipt. Software is non-refundable, fast digital delivery via email.


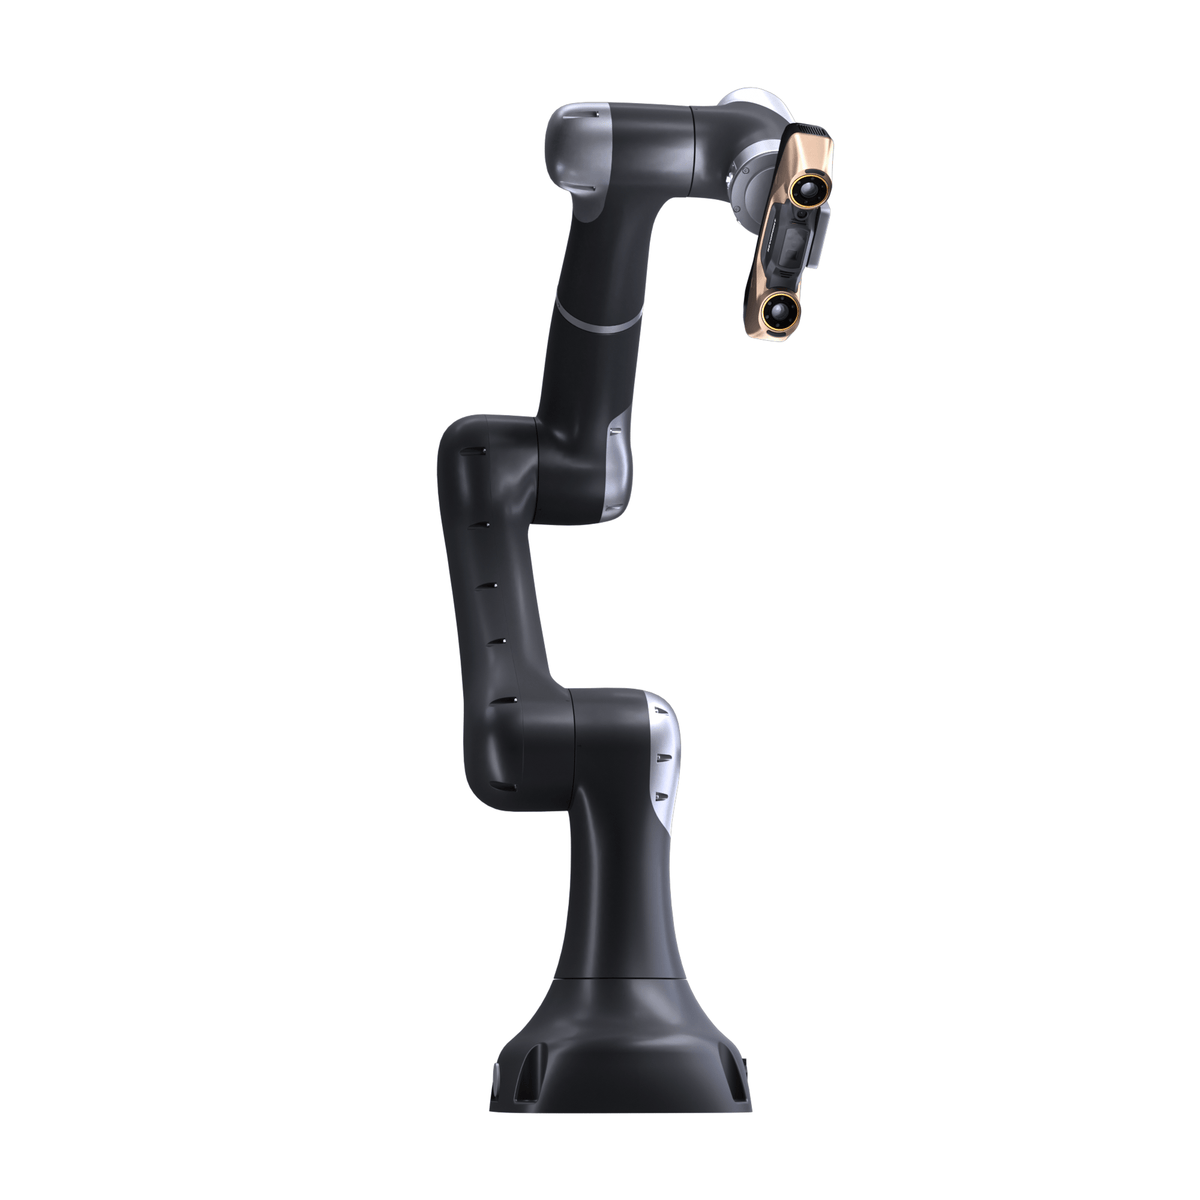
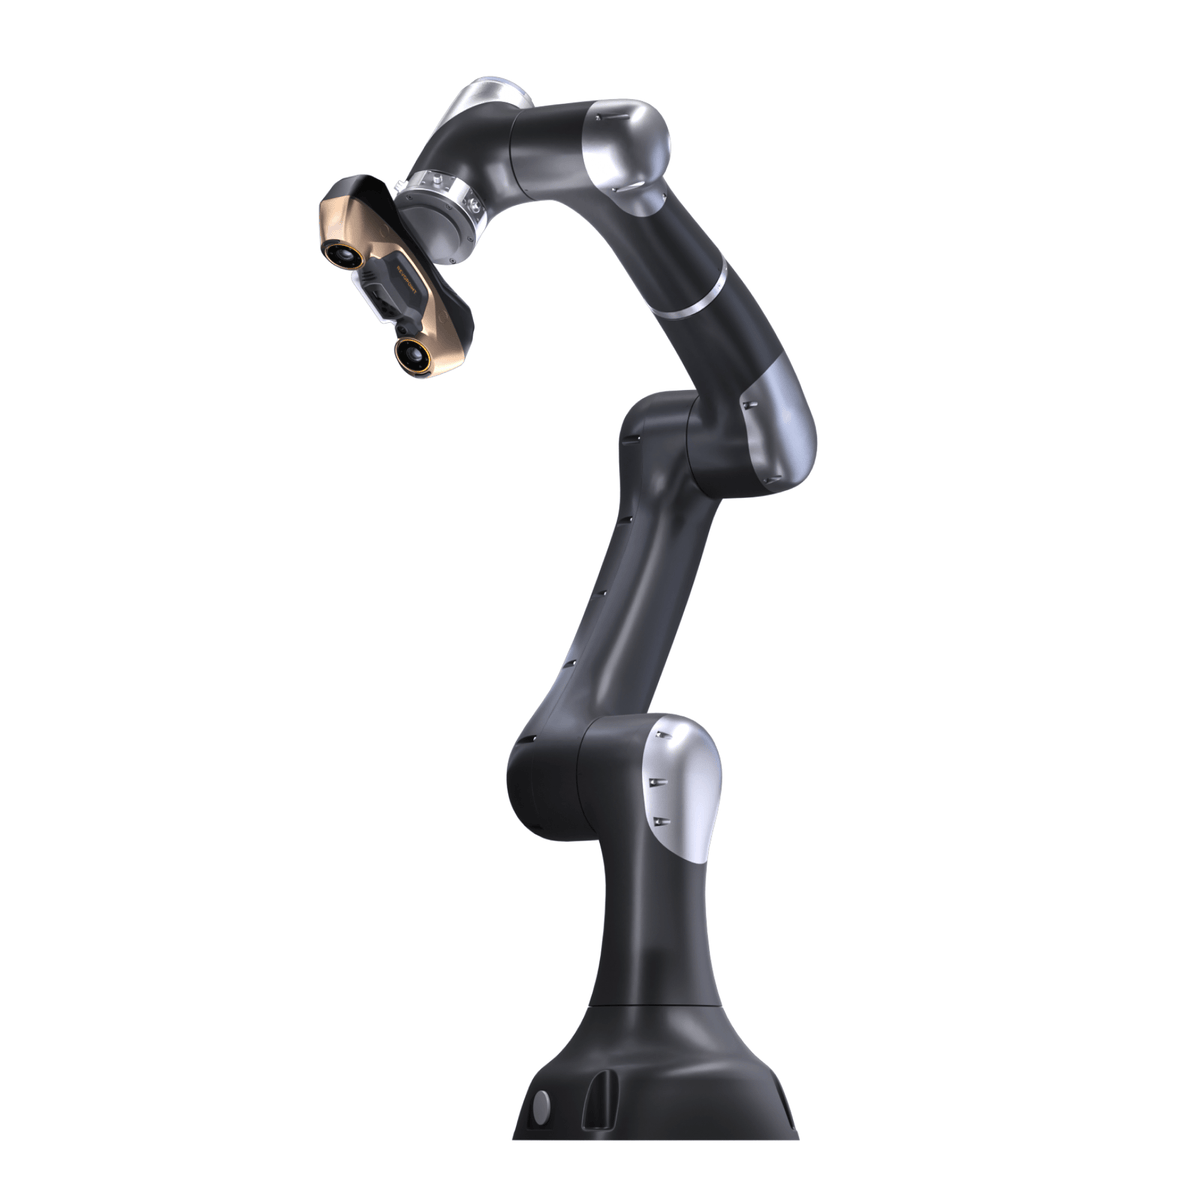
Metrohub 09YU — MetroY Ultra 3D scanner, Vbot 9 Robot, and MetroBot software for automated scanning and inspection.
Automated multi-angle scanning covers complex workpieces up to 0.5 m.
Volumetric Accuracy:
0.015 mm + 0.04 mm × L (m)
Agile Motion:
6-axis, ±360° Movement
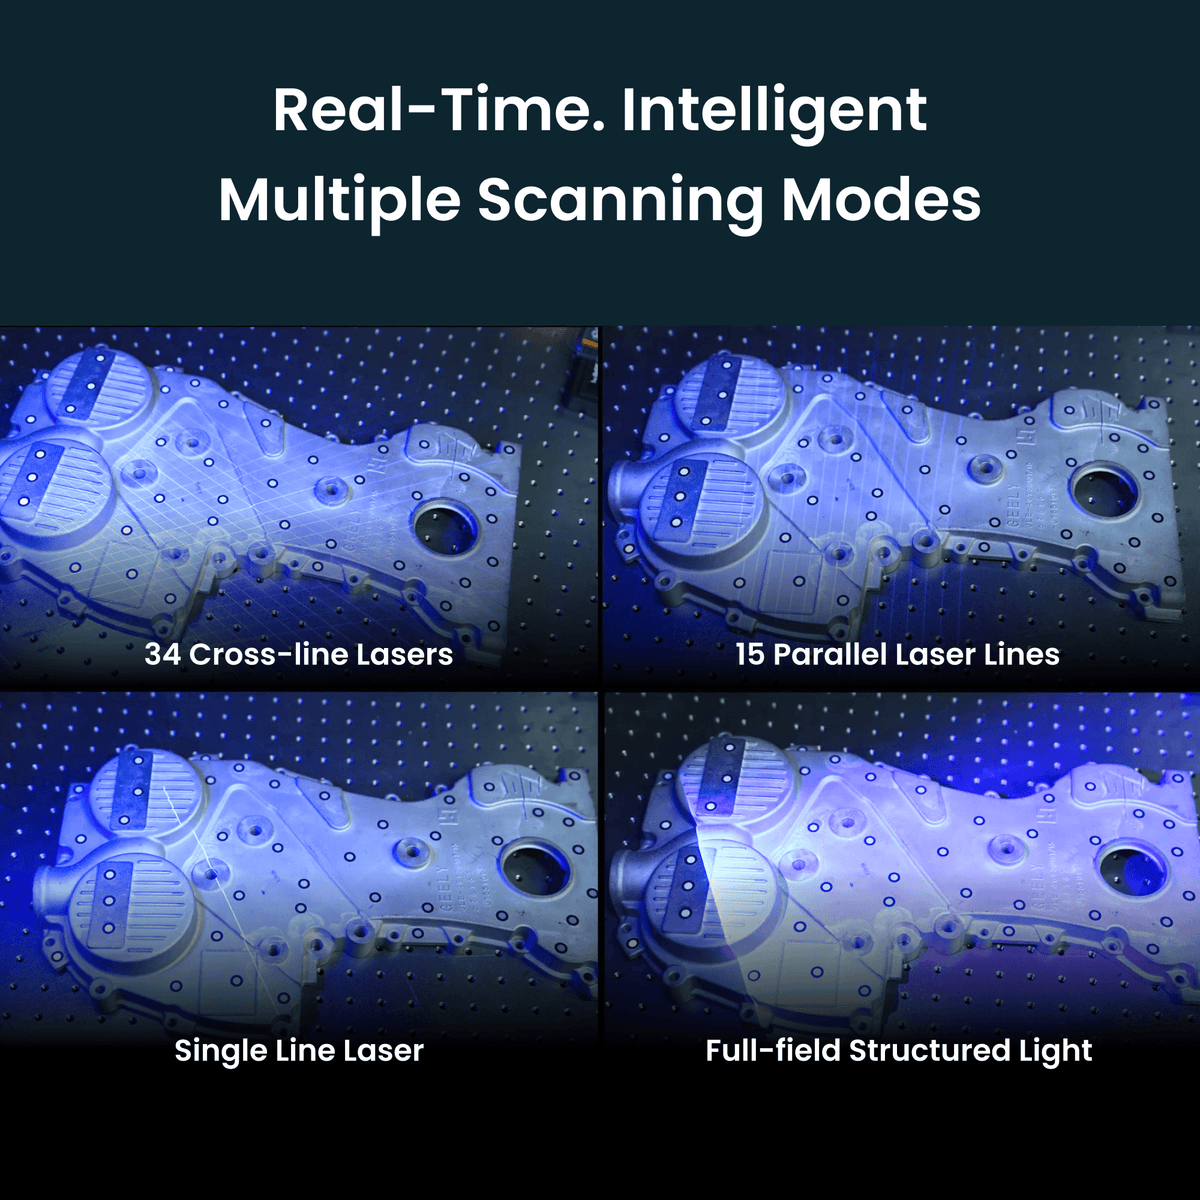
34 cross-line, 15 parallel-line, 1 deep-hole laser and 62-line full-field structured light — up to 7,000,000 points/s, capturing dark, high-reflective & complex surfaces.

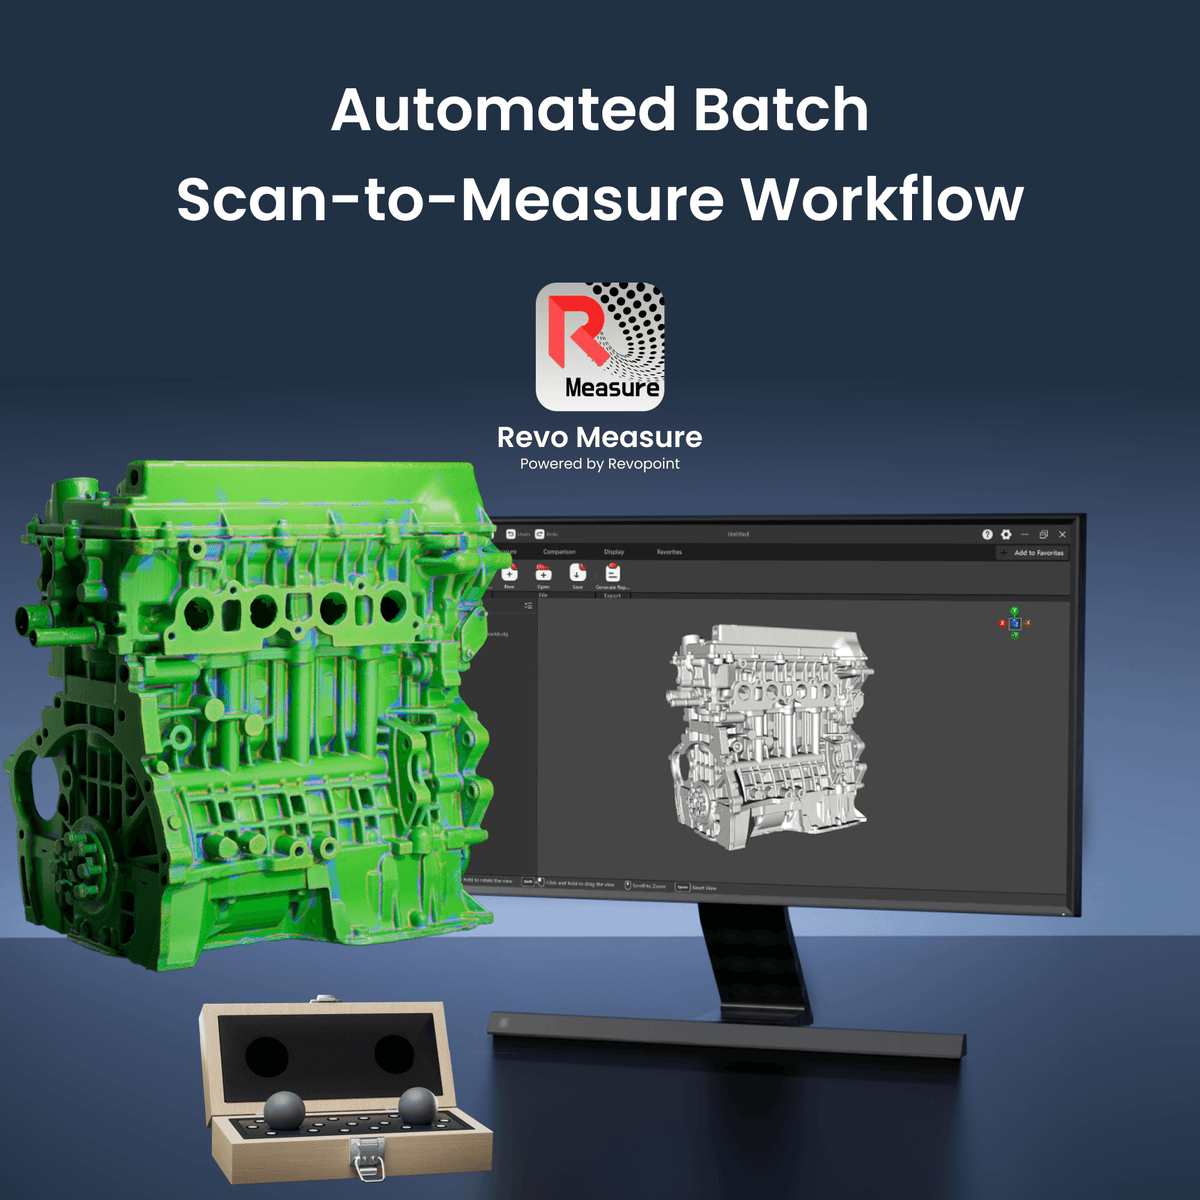
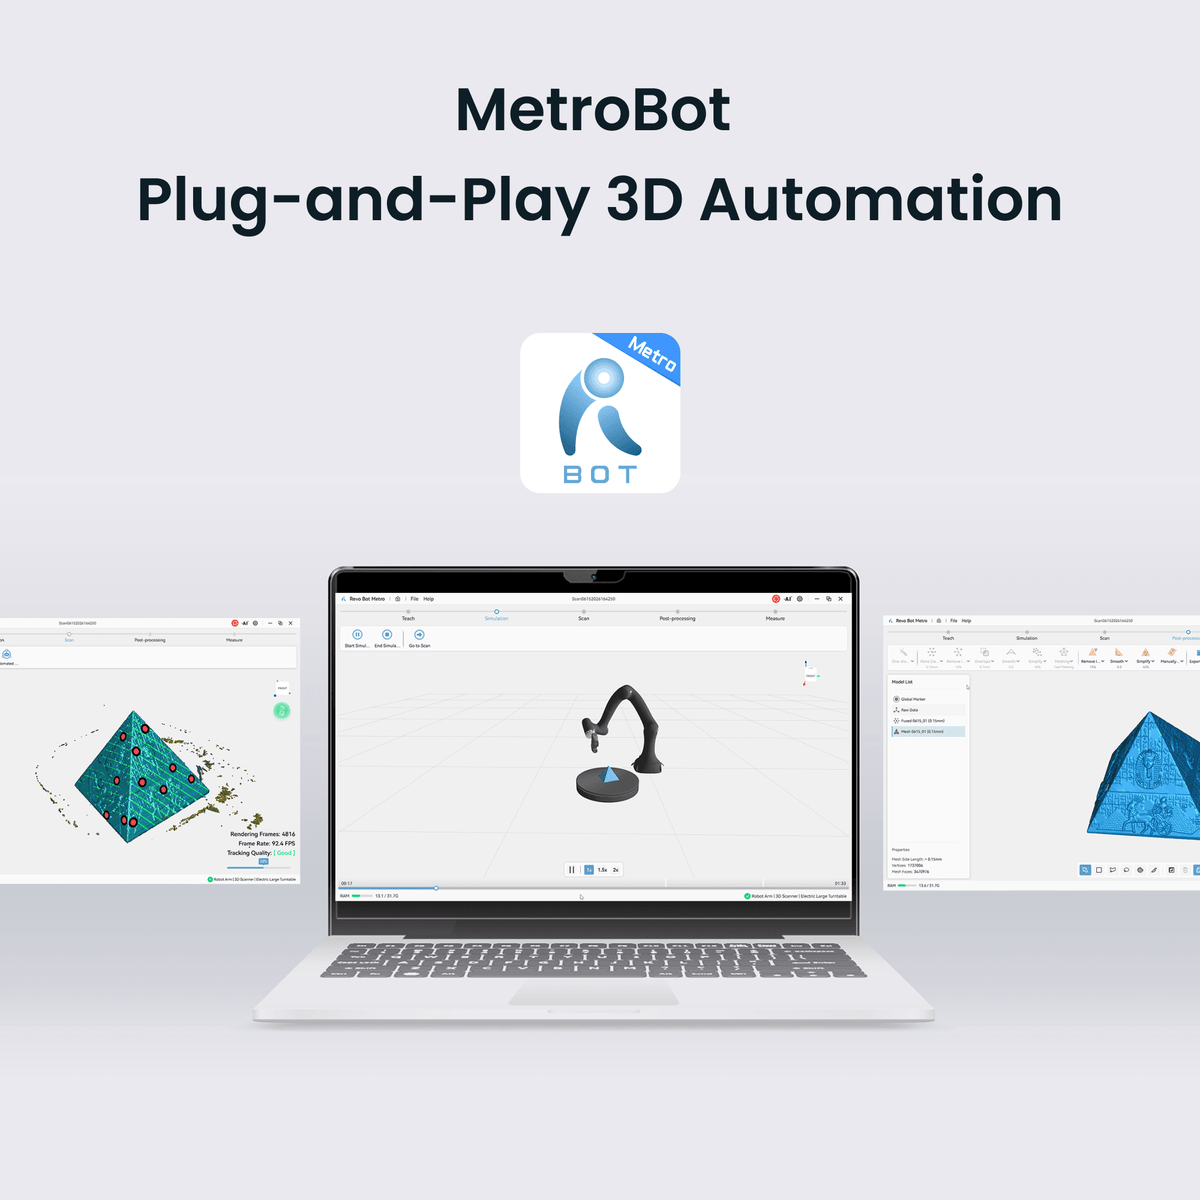
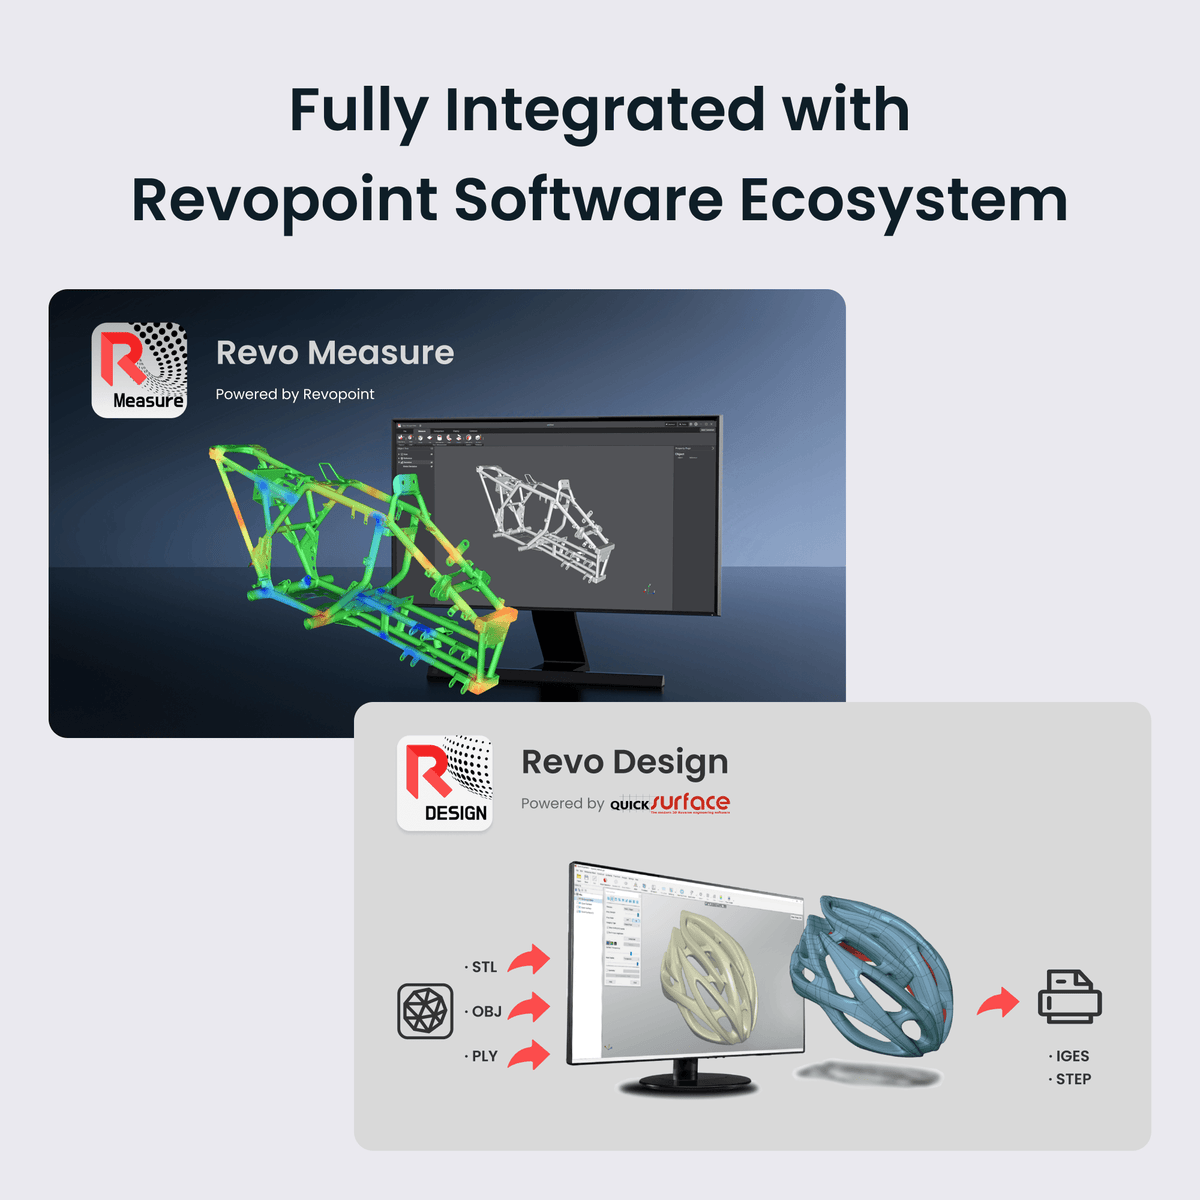
Set once, scan repeatedly — Metrohub 09YU auto-scans batch parts and flows directly into Revo Measure for GD&T output.
*Included in the CMM Edition.

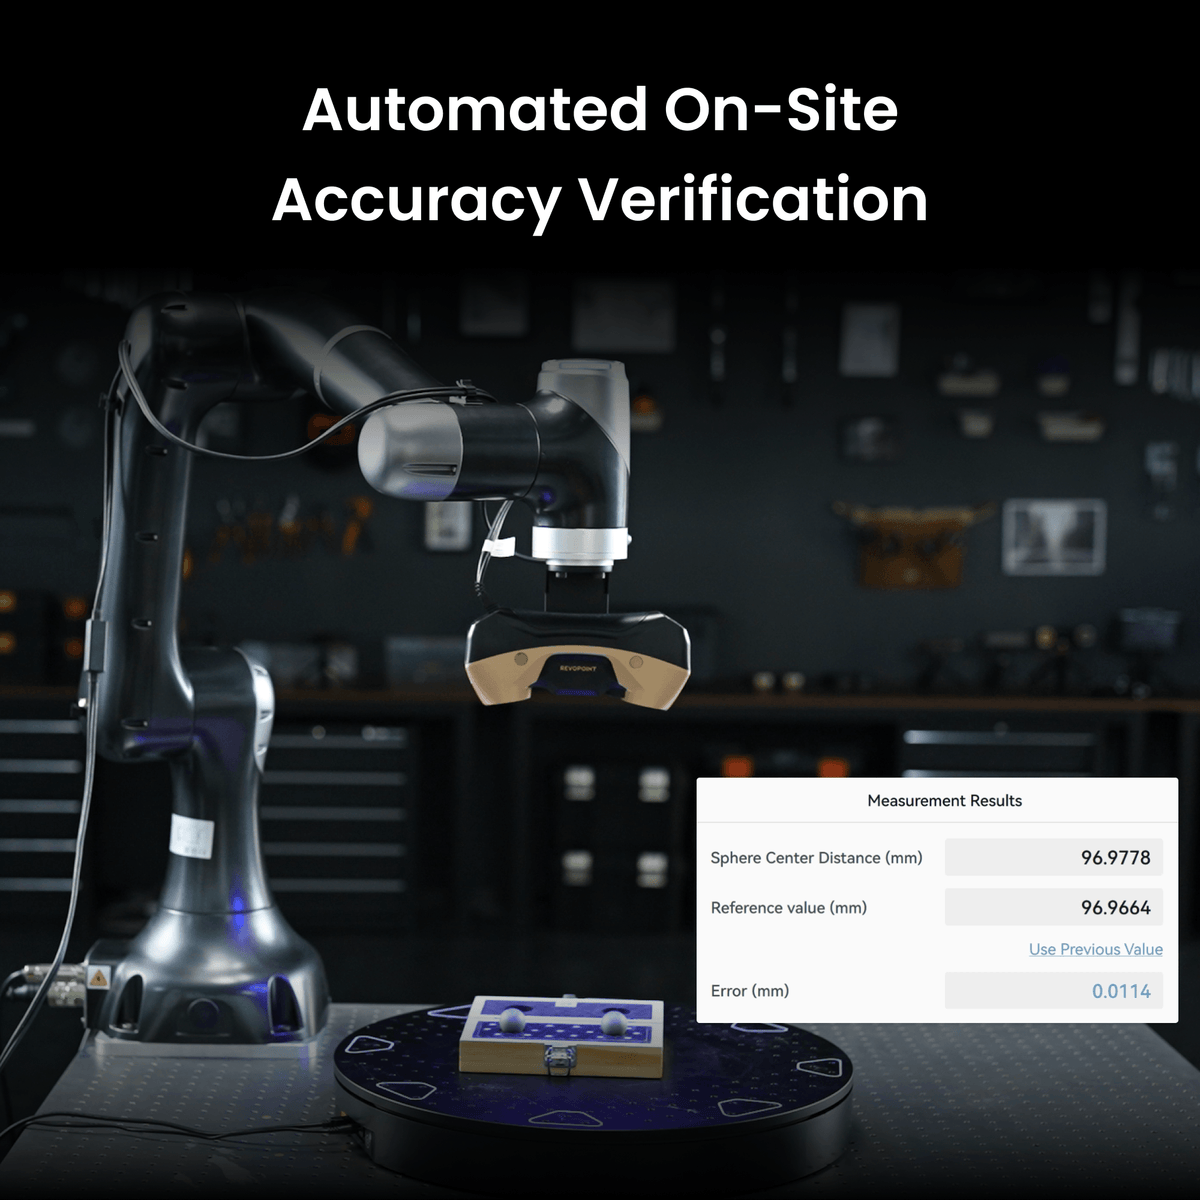
Place the *Ball Plate in MetroBot — Metrohub 09YU auto-scans, calculates, and confirms accuracy before every inspection.
*Included in the CMM Edition.

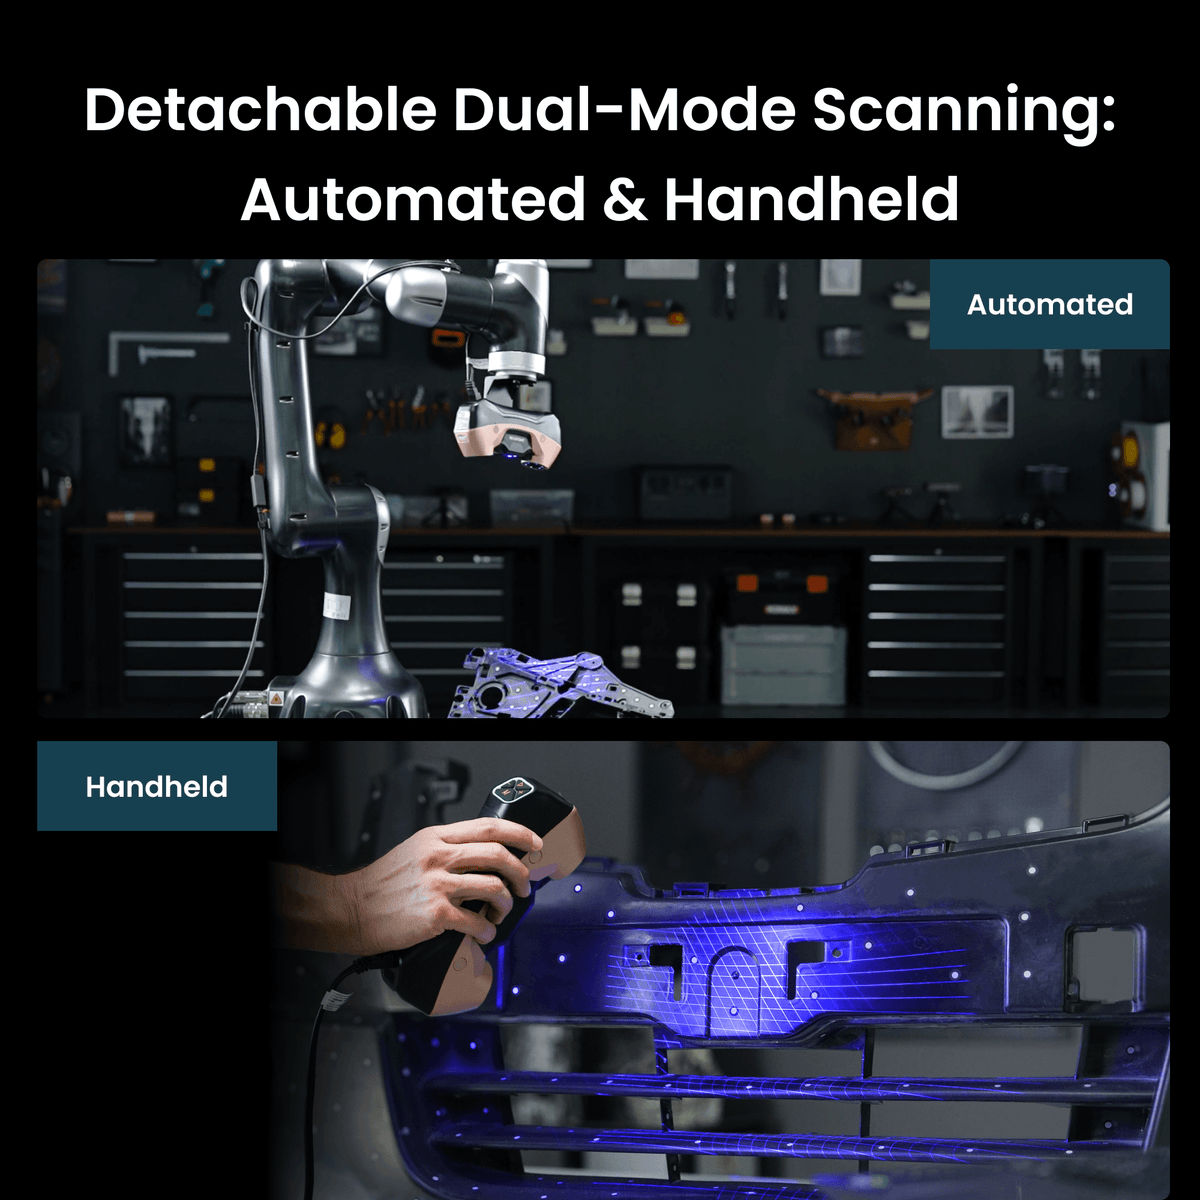
MetroY Ultra detaches for standalone handheld scanning or mounts on Vbot 9 for fully automated robotic scanning.

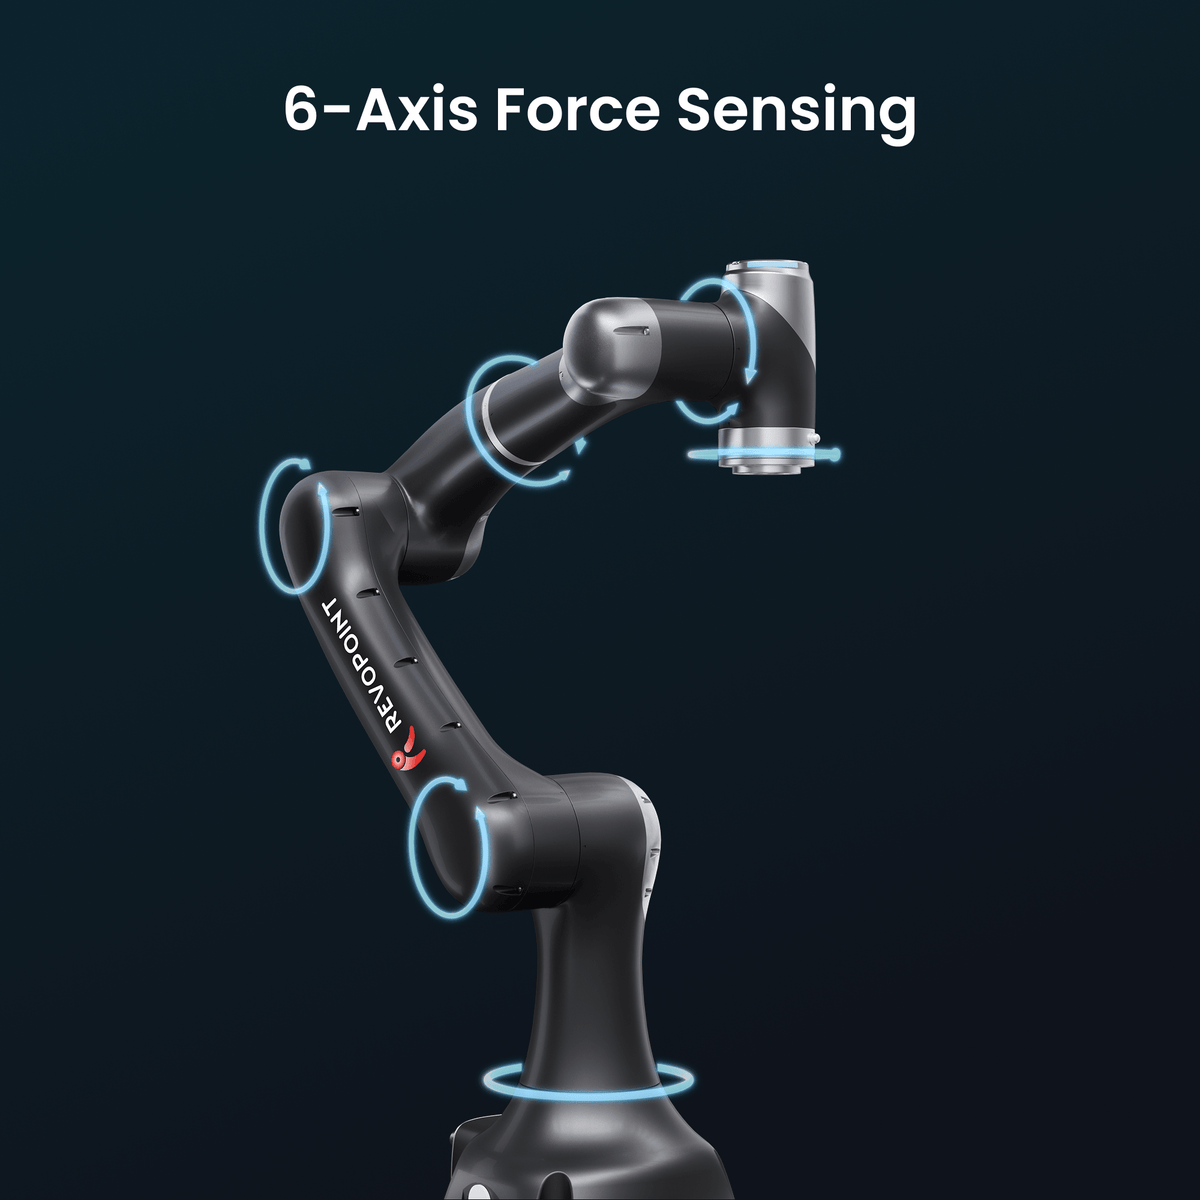
Vbot 9's integrated 6-axis force sensors deliver real-time force feedback and precise force control for high-accuracy industrial applications.

Pre-scan to verify robot paths, scan coverage, and data quality before committing to a full run.

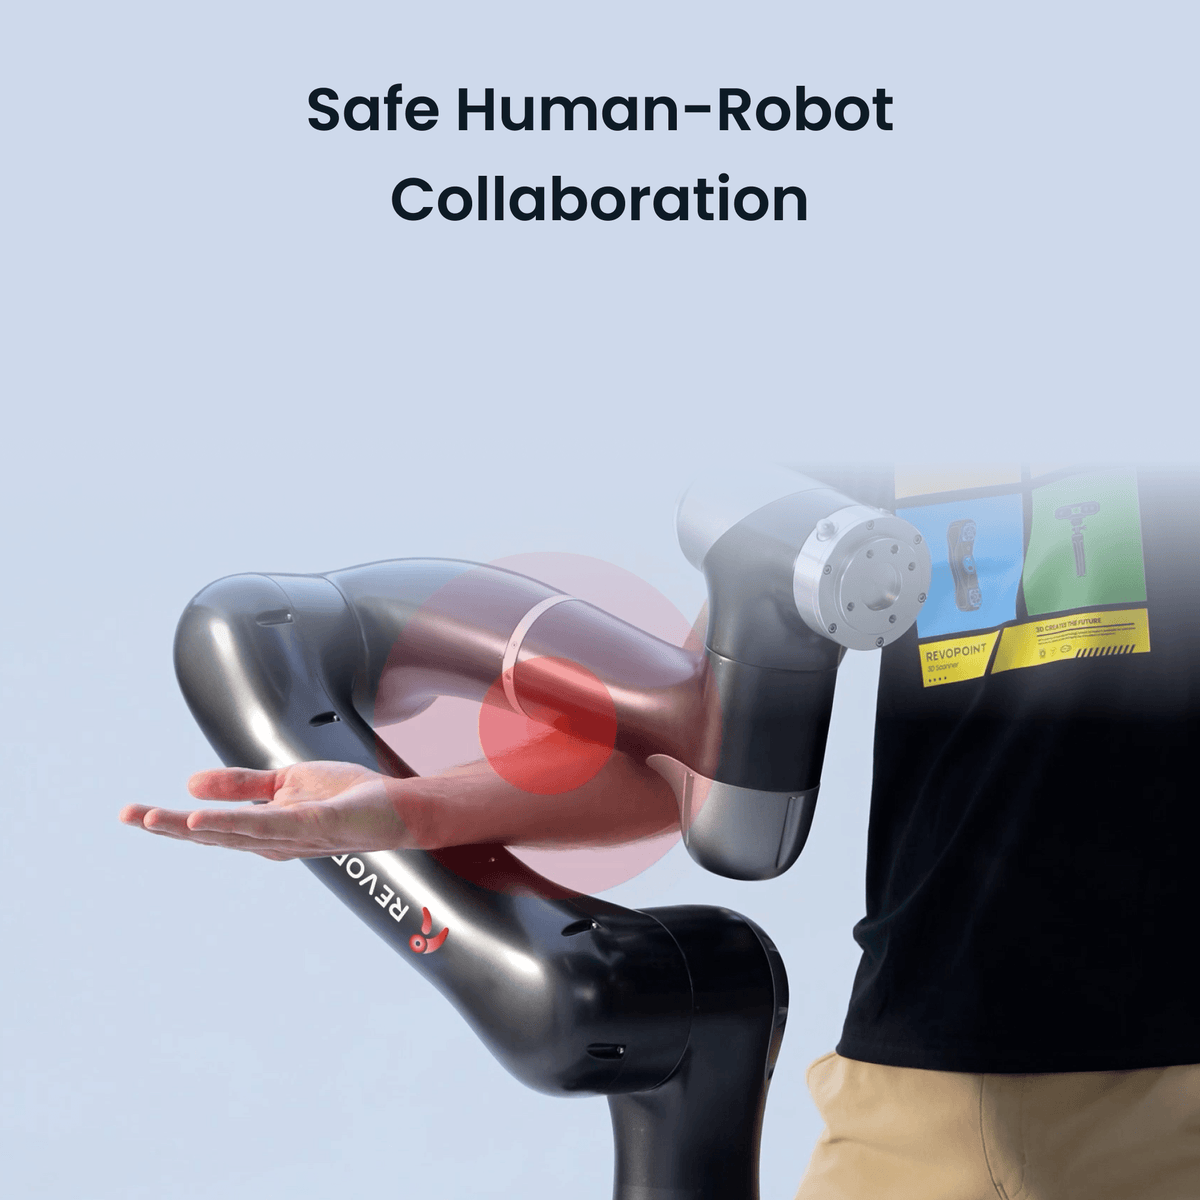
1N force sensitivity ensures collision-free human-robot collaboration — no safety fences required.

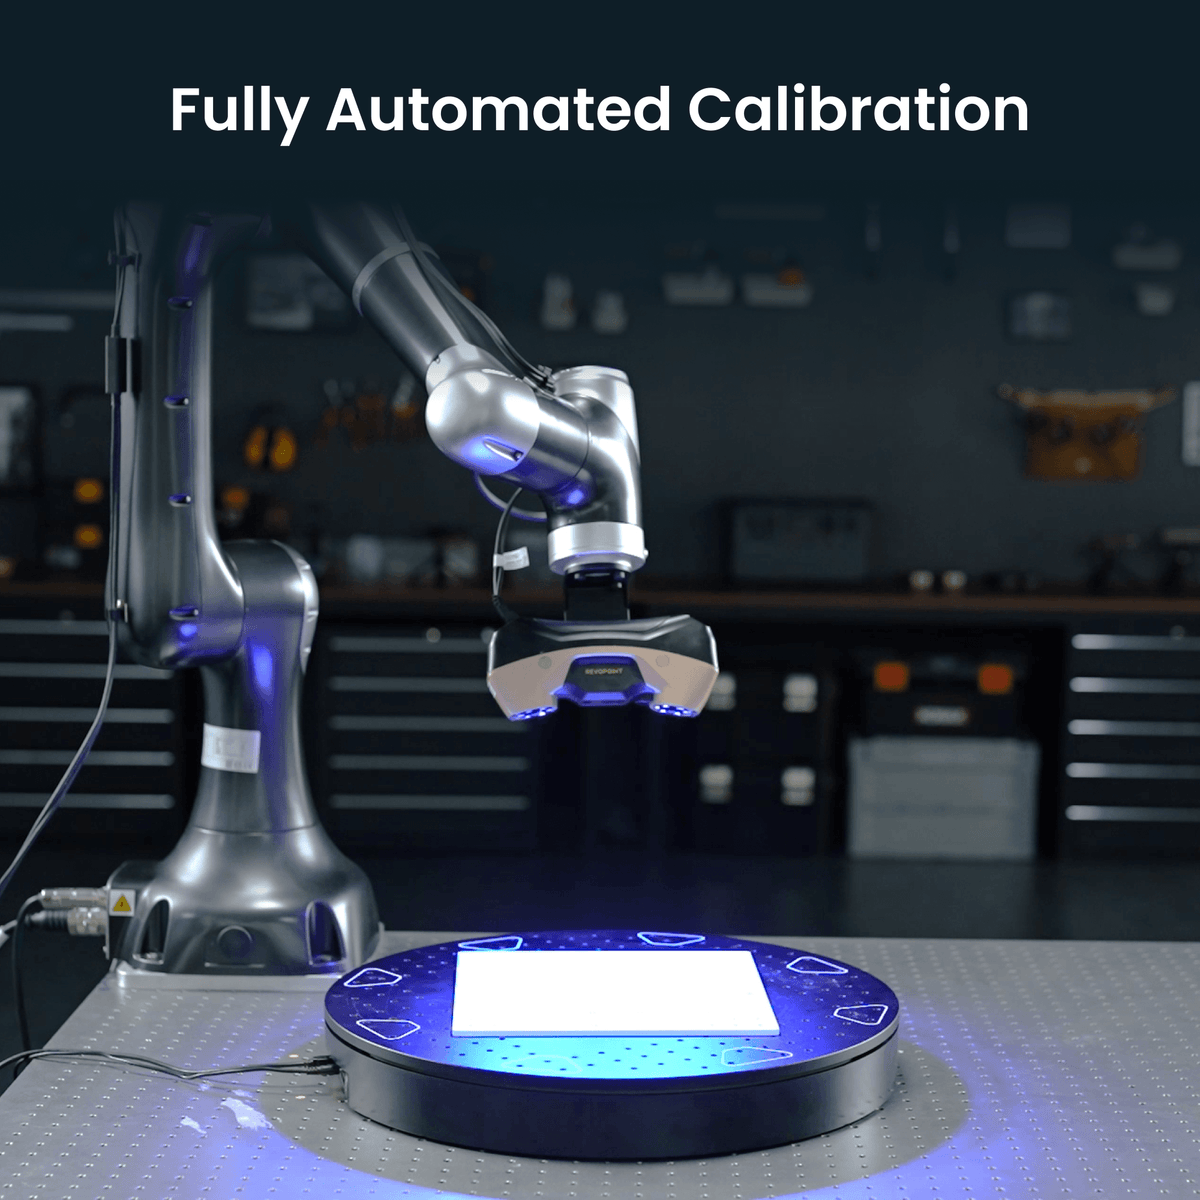
Automated calibration workflow simplifies robot, 3D Scanner, and turntable calibration — eliminating human error for reliable, repeatable results.

TCP/IP protocol enables seamless third-party integration for factory automation and batch inspection.

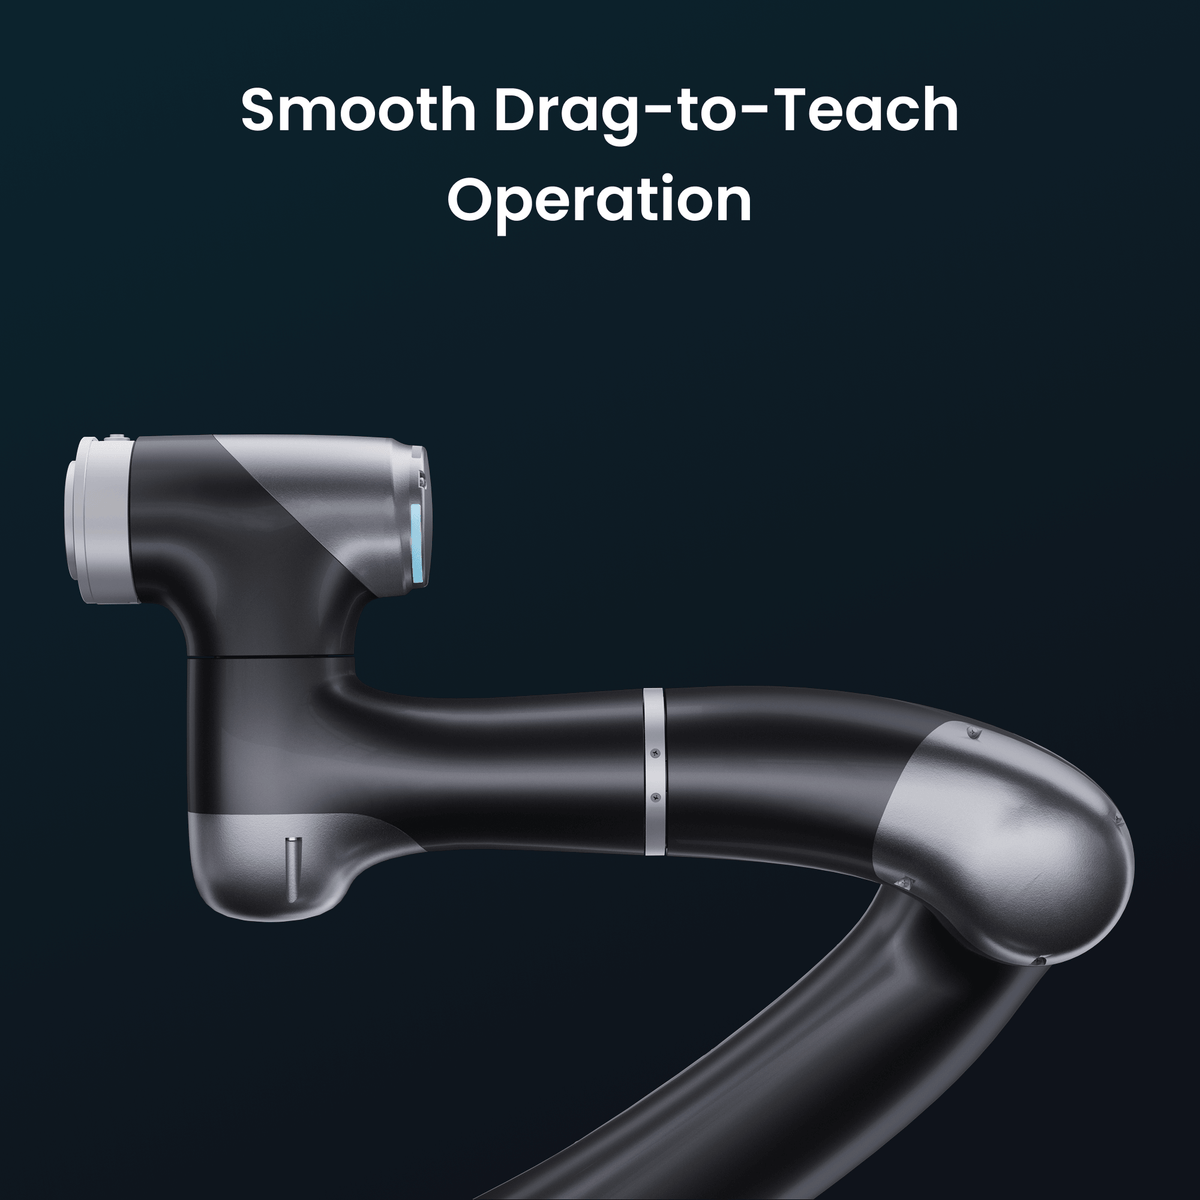
Set up automated scans in minutes with drag-to-teach, CAD-to-path, or vision-to-path — no complex programming required.

Global marker alignment builds a unified coordinate system — minimizing cumulative errors across multi-angle scans.

Integrate with Revo Measure for one-click measurements, CAD comparison, and 10+ GD&T functions.

MetroY Ultra detaches for handheld use — robotic arm or standalone scanning.

Detach the scanner for wireless, standalone scanning — ideal for complex structures, or any scenario where the robotic arm cannot reach. Maintains high-precision scanning accuracy in both robotic and handheld modes.
Learn More
Lightweight, 6-axis cobot with a 919 mm working radius and 1N force sensitivity for safe human-robot collaboration. Pairs seamlessly with the MetroY Ultra for automated multi-pose scanning across complex workpieces.
Learn MoreProfessional Solutions

Automatically plan multi-pose scan paths across blade surfaces and root features with AI collision avoidance — completing 360° point cloud capture in a single setup.

Automatically capture point clouds of overhangs, lattice structures, and internal cavities — generating STL data for model repair, process compensation, and remanufacturing.

Scan castings and hot workpieces automatically with real-time thermal compensation — rapidly identifying stock deviation, shrinkage, and surface defects to accelerate mold correction.

Automated inspection for injection-molded, blow-molded, and thermoformed parts — detecting shrinkage, warping, springback, and contour deformation across batch production.

Automatically scan weld seams, hole positions, and surface profiles on automotive body panels — comparing point clouds against CAD with open TCP/IP interfaces for production line integration.

Multi-pose robotic scanning covers all six faces, sealing zones, and terminals of prismatic battery housings — detecting bulging, dents, sealing misalignment, and dimensional deviations.
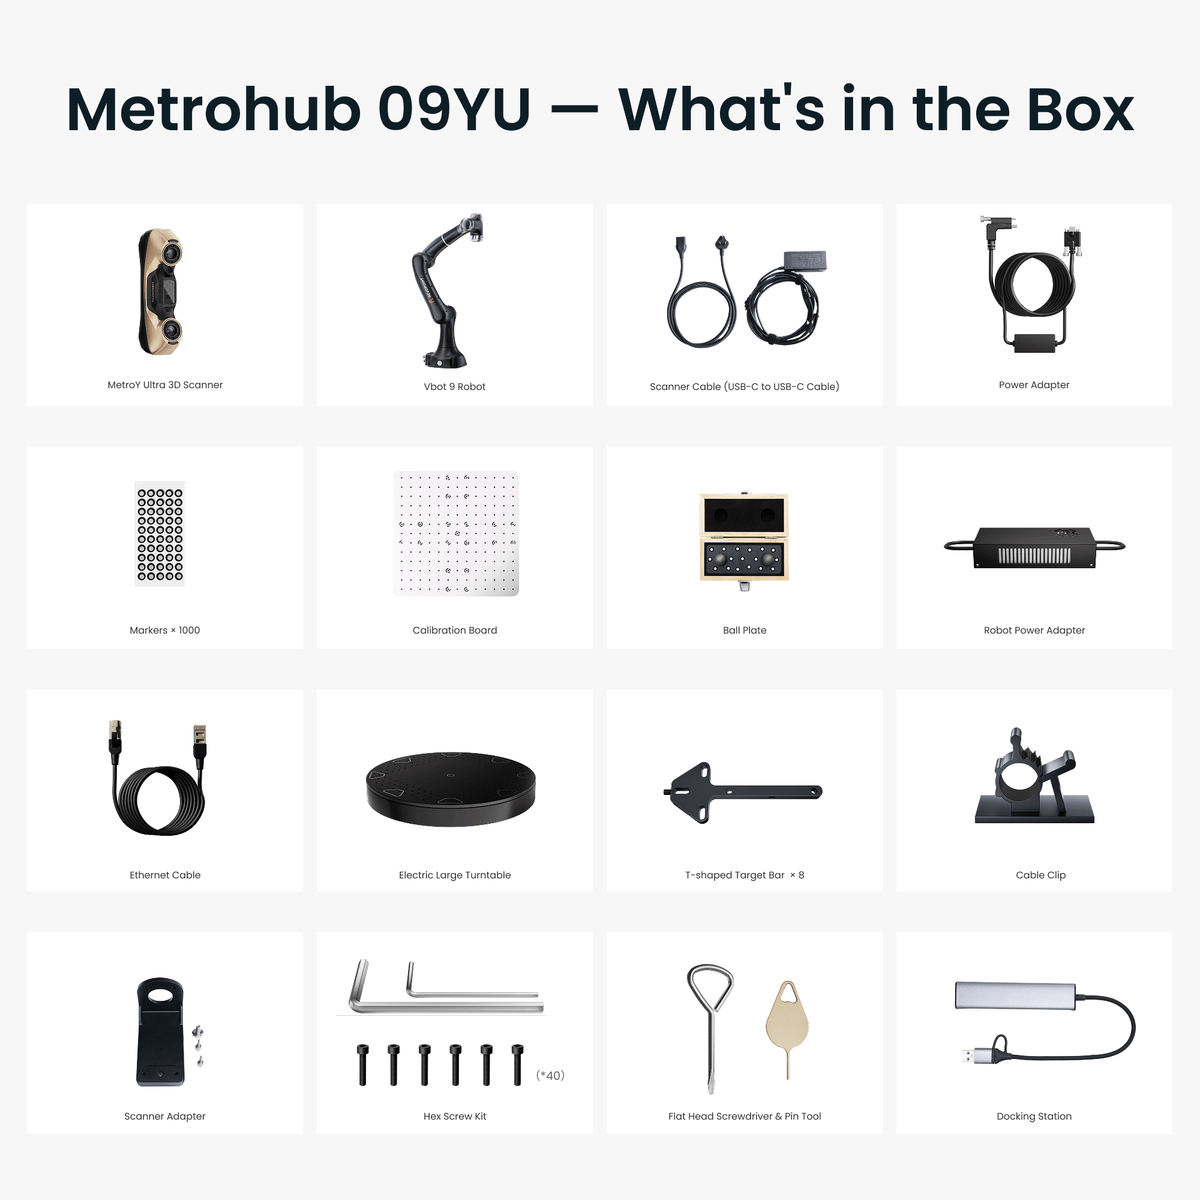
What’s in the Box?

MetroY Ultra 3D Scanner

Vbot 9 Robot

Scanner Cable
(USB-C to USB-C Cable)

Power Adapter

Markers × 1000

Calibration Board

Ball Plate

Robot Power Adapter

Ethernet Cable

Electric Large Turntable

T-shaped Target Bar × 8

Cable Clip

Scanner Adapter

Hex Screw Kit

Flat Head Screwdriver

Pin Tool

Docking Station
| Metrohub 09YU Robot 3D Scanning System | |
|---|---|
| Main components | Metrohub 09YU, Robot Vbot 9 |
| Metrohub 09YU Volumetric Accuracy① | 0.015 mm + 0.04 mm × L (m) |
| Scannable Object Dimensions | ∅500 mm × H 500 mm |
| Worktable Mounting Dimensions (L × W × H) | 90 × 90 × 80 cm |
| Robot Arm Operating Radius | 919 mm |
| Shipping Dimensions | 91 × 55 × 52 cm |
| Total Weight | 39 kg |
| MetroY Ultra 3D Scanner | |
|---|---|
|
MetroY Ultra

|
|
| Technology | Multi-line Laser Scan and Full-field Structured Light Scan |
| Scannable Object Size | Small to Medium |
| Single-frame Precision, up to | 0.01 mm |
| Single-frame Accuracy, up to | 0.015 mm |
| Volumetric Accuracy | 0.015 mm + 0.04 mm × L (m), L is the length of the object. |
| Fused Point Distance, up to | 0.05 mm |
| Working Distance | 200 ~ 400 mm |
| Single Capture Area at Nearest Distance | 152 × 138 mm at 200 mm |
| Single Capture Area at Furthest Distance | 332 × 276 mm at 400 mm |
| Angular Field of View (H × V) | 49 × 38° |
| Minimum Scan Volume | 10 × 10 × 10 mm |
| Maximum Scan Volume | 2 × 2 × 2 m |
| Scanning Speed, up to | NVIDIA GPU: 90 fps CPU: 60 fps |
| Point Return Rate | Multi-line Laser Scan: 3,000,000 Points/s Full-field Structured Light Scan: 7,000,000 Points/s |
| RGB Camera Resolution | 2 Megapixels |
| Tracking Methods | Global Marker |
| 3D Light Source | 34 Blue Cross Laser Lines 15 Blue Parallel Laser Lines 1 Blue Deep Hole Single Laser Line 62 Line Blue Full-field Structured Light |
| Fill Lights | 12 Blue LEDs |
| CPU | 4 core ARM, 2.0 GHz |
| Built-in Chip Computing | Depth Computing |
| Buttons | 4 |
| Output File Formats | PLY, OBJ, STL, ASC, 3MF, GLTF, FBX |
| Ready to Print 3D Models | ✔ |
| Wi-Fi | 6 |
| Connector Type | USB Type-C to Type-C |
| Power Requirements | DC 12V, 3A |
| Scanner Weight | 450 g |
| Dimensions (L × W × H) | 211 × 94 × 47 mm |
| Special Object Scanning | Please use scanning spray when scanning transparent or specular surfaces in Laser Line modes. Using scanning spray is recommended when scanning transparent, black, specular, or highly reflective surfaces in Full-Field Structured Light modes. |
| User Recalibration | Yes |
| Robot Specifications | ||
|---|---|---|
|
Vbot 9

|
||
| Robot | Vbot 9 | |
| Load | 5 kg | |
| Working Radius | 919 mm | |
| Weight | 17.5 kg | |
| Number of Axes | 6 | |
| Maximum TCP Speed | ≤2.0 m/s | |
| Operating Temperature | 0°C ~ +50°C | |
| Storage Temperature | -10°C ~ +55°C | |
| Maximum Humidity | 0%~93%, non-condensing, non-frosting | |
| Noise level | ≤70dB(A) | |
| Control Type | Built-in | |
| Joint Range of Motion (ROM) | Axis J1 | ±360° |
| Axis J2 | ±135° | |
| Axis J3 | -170° ~ +140° | |
| Axis J4 | ±360° | |
| Axis J5 | ±360° | |
| Axis J6 | ±360° | |
| Single-Joint Speed | Axis J1 | 180°/s |
| Axis J2 | 180°/s | |
| Axis J3 | 180°/s | |
| Axis J4 | 180°/s | |
| Axis J5 | 180°/s | |
| Axis J6 | 180°/s | |
| Note 1. Volumetric Accuracy are acquired in a controlled lab environment. Actual results might vary, subject to the operation environment. 2. Class 2M Laser Safety Tips: (1) The product uses a Class 2M laser projector. Avoid looking directly at it at close range! Please refer to the Class 2M laser standard document for details. (2) To avoid retina damage, don't look directly into the laser beam through optical instruments capable of magnifying it (e.g., telescopes, and camera lenses). (3) To prevent laser reflection, avoid placing reflective surfaces like mirrors or glass in the path of the laser beam. 3. To ensure accuracy, it's recommended to use the product within an environment temperature range of 20℃ to 25℃ (68℉ to 77℉). 4. This product has flashing lights, which may not be suitable for people with photosensitive epilepsy. |
||
Yes. A TCP/IP-based software control protocol is provided, enabling you to program the robot scanner software to start, scan, stop, and acquire data.
No, other brands are not currently supported.
MetroY Ultra 3D Scanner, Vbot 9, Robot Power Adapter, Electric Large Turntable, and MetroBot Auto Scanning Software.
No teach pendant is required. It supports manual drag-to-teach and 3D visualization-based teaching for intuitive, straightforward setup.
Both are built around the Vbot 9 6-axis collaborative robot but use different scanning technologies. The 09YU integrates the MetroY Ultra, combining multi-line blue laser and full-field blue structured light for fine feature capture and high-speed data acquisition. The 09TR integrates the Trackit SR optical tracking scanner, using blue laser with a Tracker for real-time positioning — enabling marker-free tracking and flexible turntable-assisted scanning.
(1) Accuracy: Metrohub 09YU provides volumetric accuracy of 0.015 mm + 0.04 mm × L (m) for precision detail capture. Metrohub 09TR provides 0.025 mm + 0.04 mm × L (m) for stable markerless scans.
(2) Speed: Metrohub 09YU reaches 3,000,000 points/s in multi-line laser mode and 7,000,000 points/s in full-field blue structured-light mode. Metrohub 09TR reaches 2,000,000 points/s for coordinated robot and optical-tracking acquisition.
Both systems use the Vbot 9 6-axis robot for automated multi-angle scanning. Metrohub 09YU primarily requires the scanner, robot, and turntable. Metrohub 09TR also requires a Tracker, with the Scanner, workpiece, and turntable kept within the Tracker’s effective field of view.
Metrohub 09YU uses MetroBot, while Metrohub 09TR uses TrackBot. Both support robot teaching, path simulation, automated scanning, ball-plate measurement, model post-processing, and one-click transfer to measurement software, covering the complete workflow from scan planning to data application.
Metrohub 09YU supports laser-line and full-field scanning. Blue laser lines capture complex geometry and fine details for industrial measurement; full-field blue structured light reaches up to 7,000,000 points/s for rapid models.
Metrohub 09TR supports stationary and turntable tracking. Stationary tracking suits smaller workpieces; turntable tracking coordinates the Tracker, Scanner, robot, and turntable for larger-workpiece capture.
Metrohub 09YU switches between laser-line and full-field high-speed modes according to the workpiece. A global-marker environment must be established before scanning for stable positioning and data stitching.
Metrohub 09TR manages the Tracker’s field of view, hand-eye calibration, robot teaching paths, and turntable coordination. In stationary tracking mode, the Tracker and workpiece must remain still during scanning.
For precision dimensional inspection, CAD deviation analysis, fine feature capture, or high-speed scanning of small-to-medium workpieces, choose the Metrohub 09YU (volumetric accuracy: 0.015 mm + 0.04 mm × L(m); laser line & full-field blue structured light). For complex surfaces, deep holes, freeform parts, or on-site spot checks requiring optical tracking flexibility with minimal marker prep, choose the Metrohub 09TR. Both support automated inspection, reverse engineering, and quality control.